
fig5
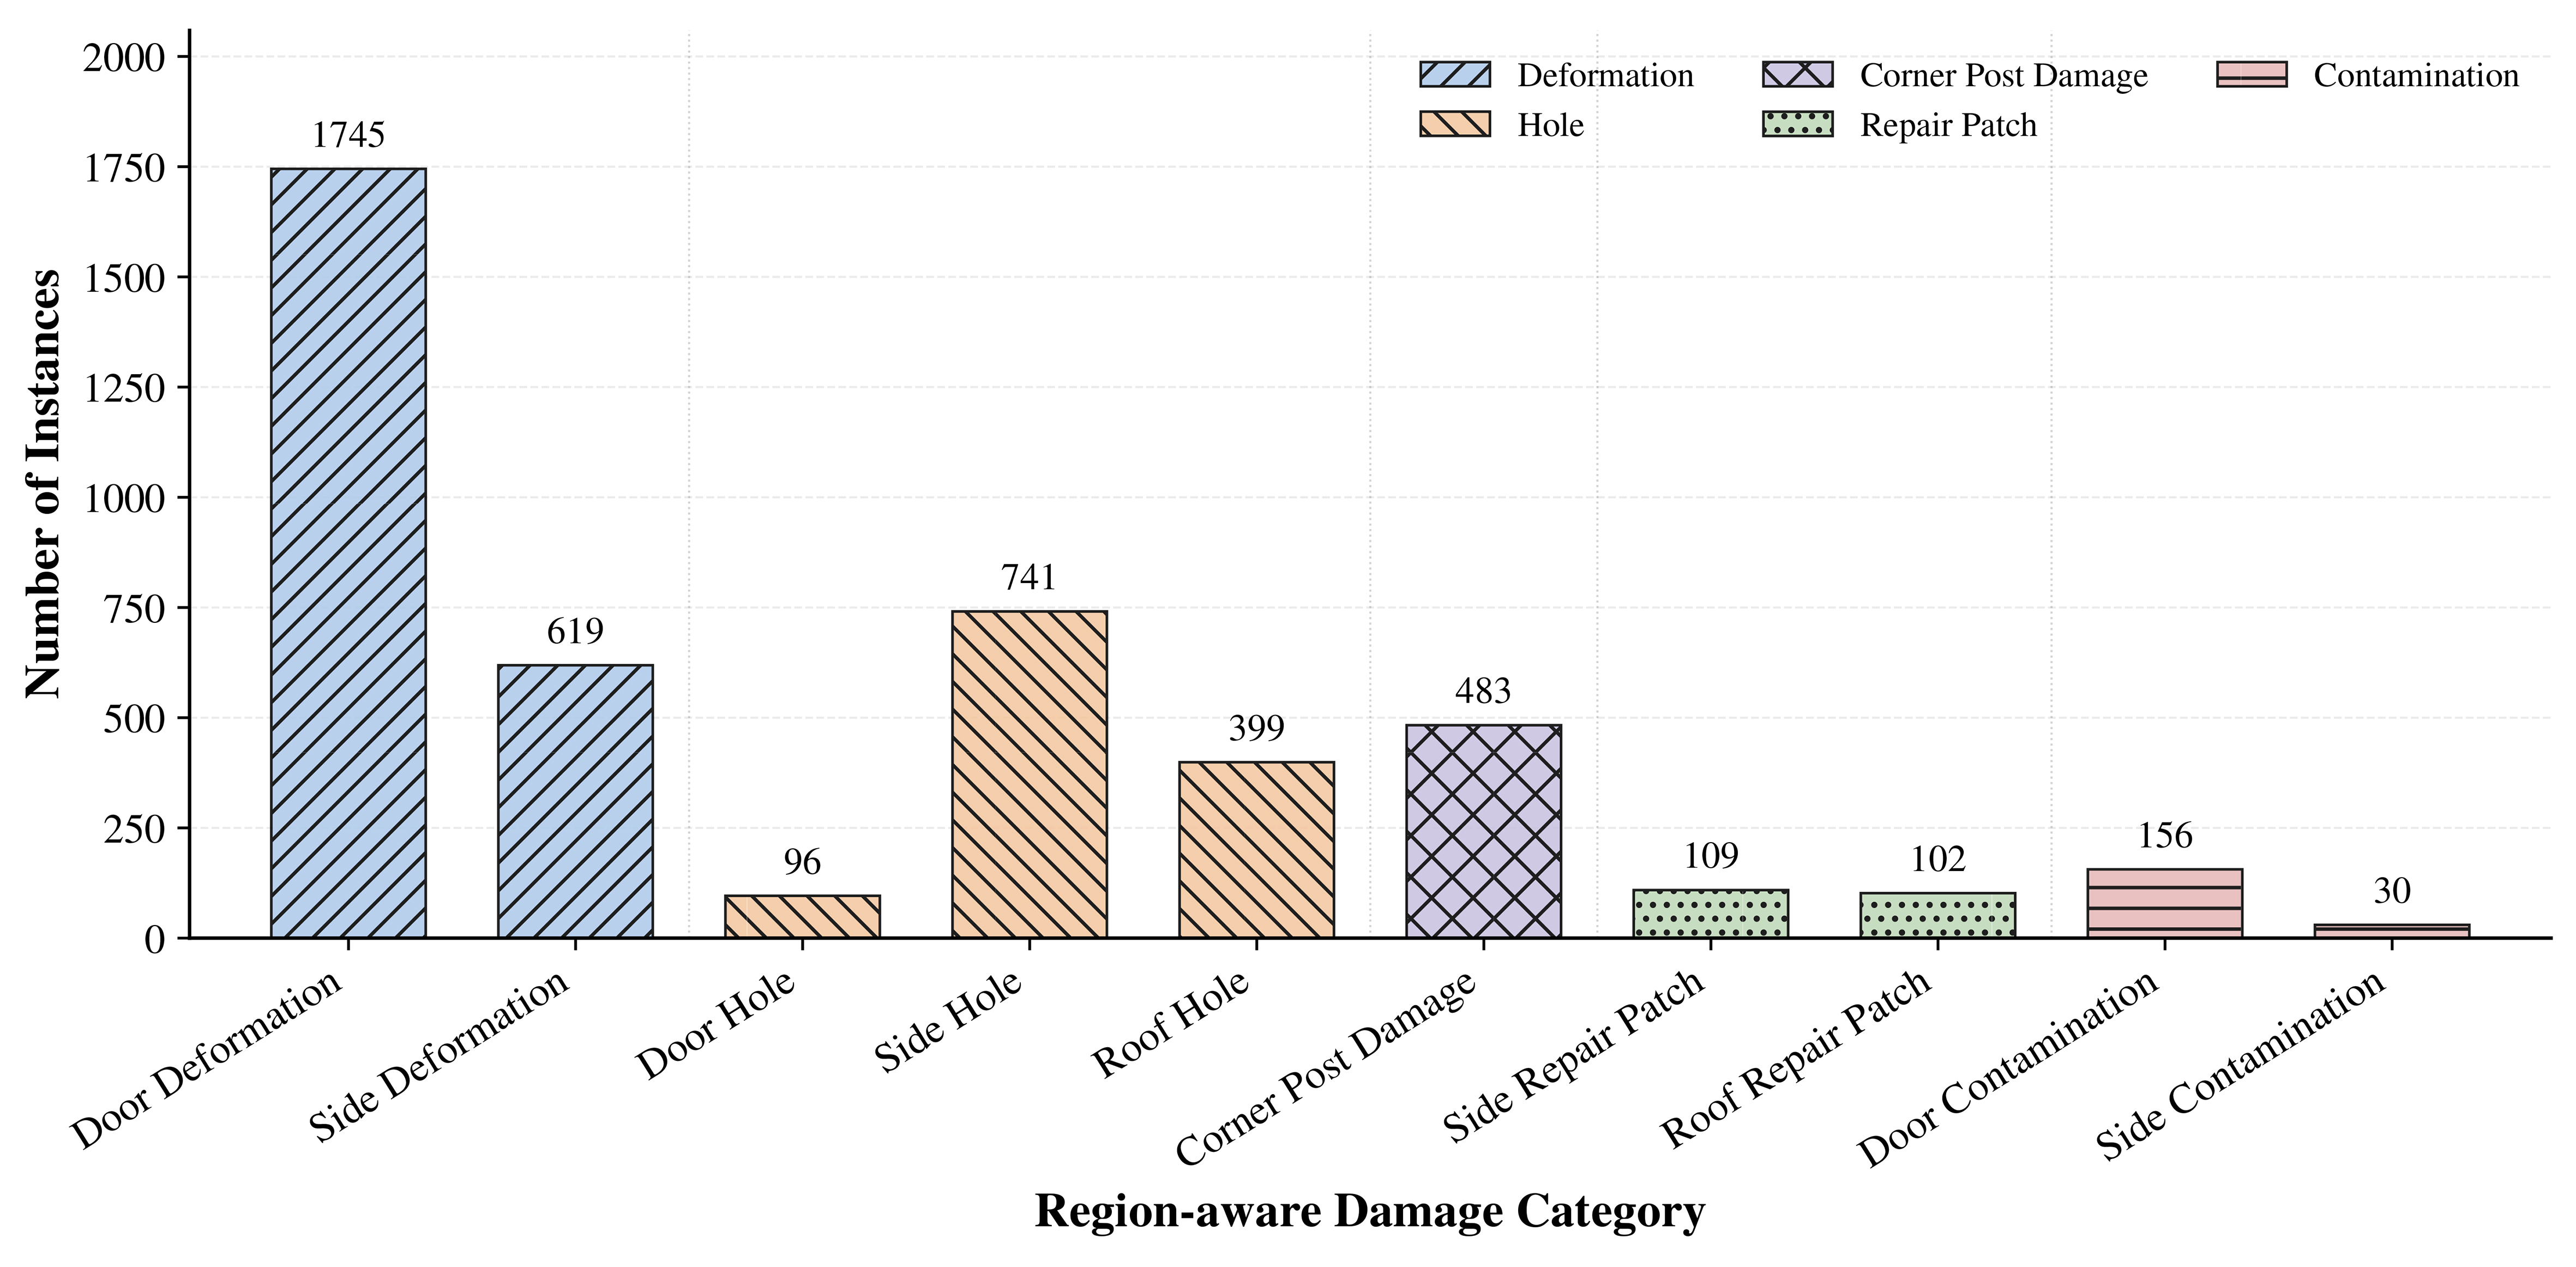
Figure 5. Region-aware defect label distribution of the container defect dataset.
Figure 5. Region-aware defect label distribution of the container defect dataset.
All published articles are preserved here permanently:
https://www.portico.org/publishers/oae/