
fig1
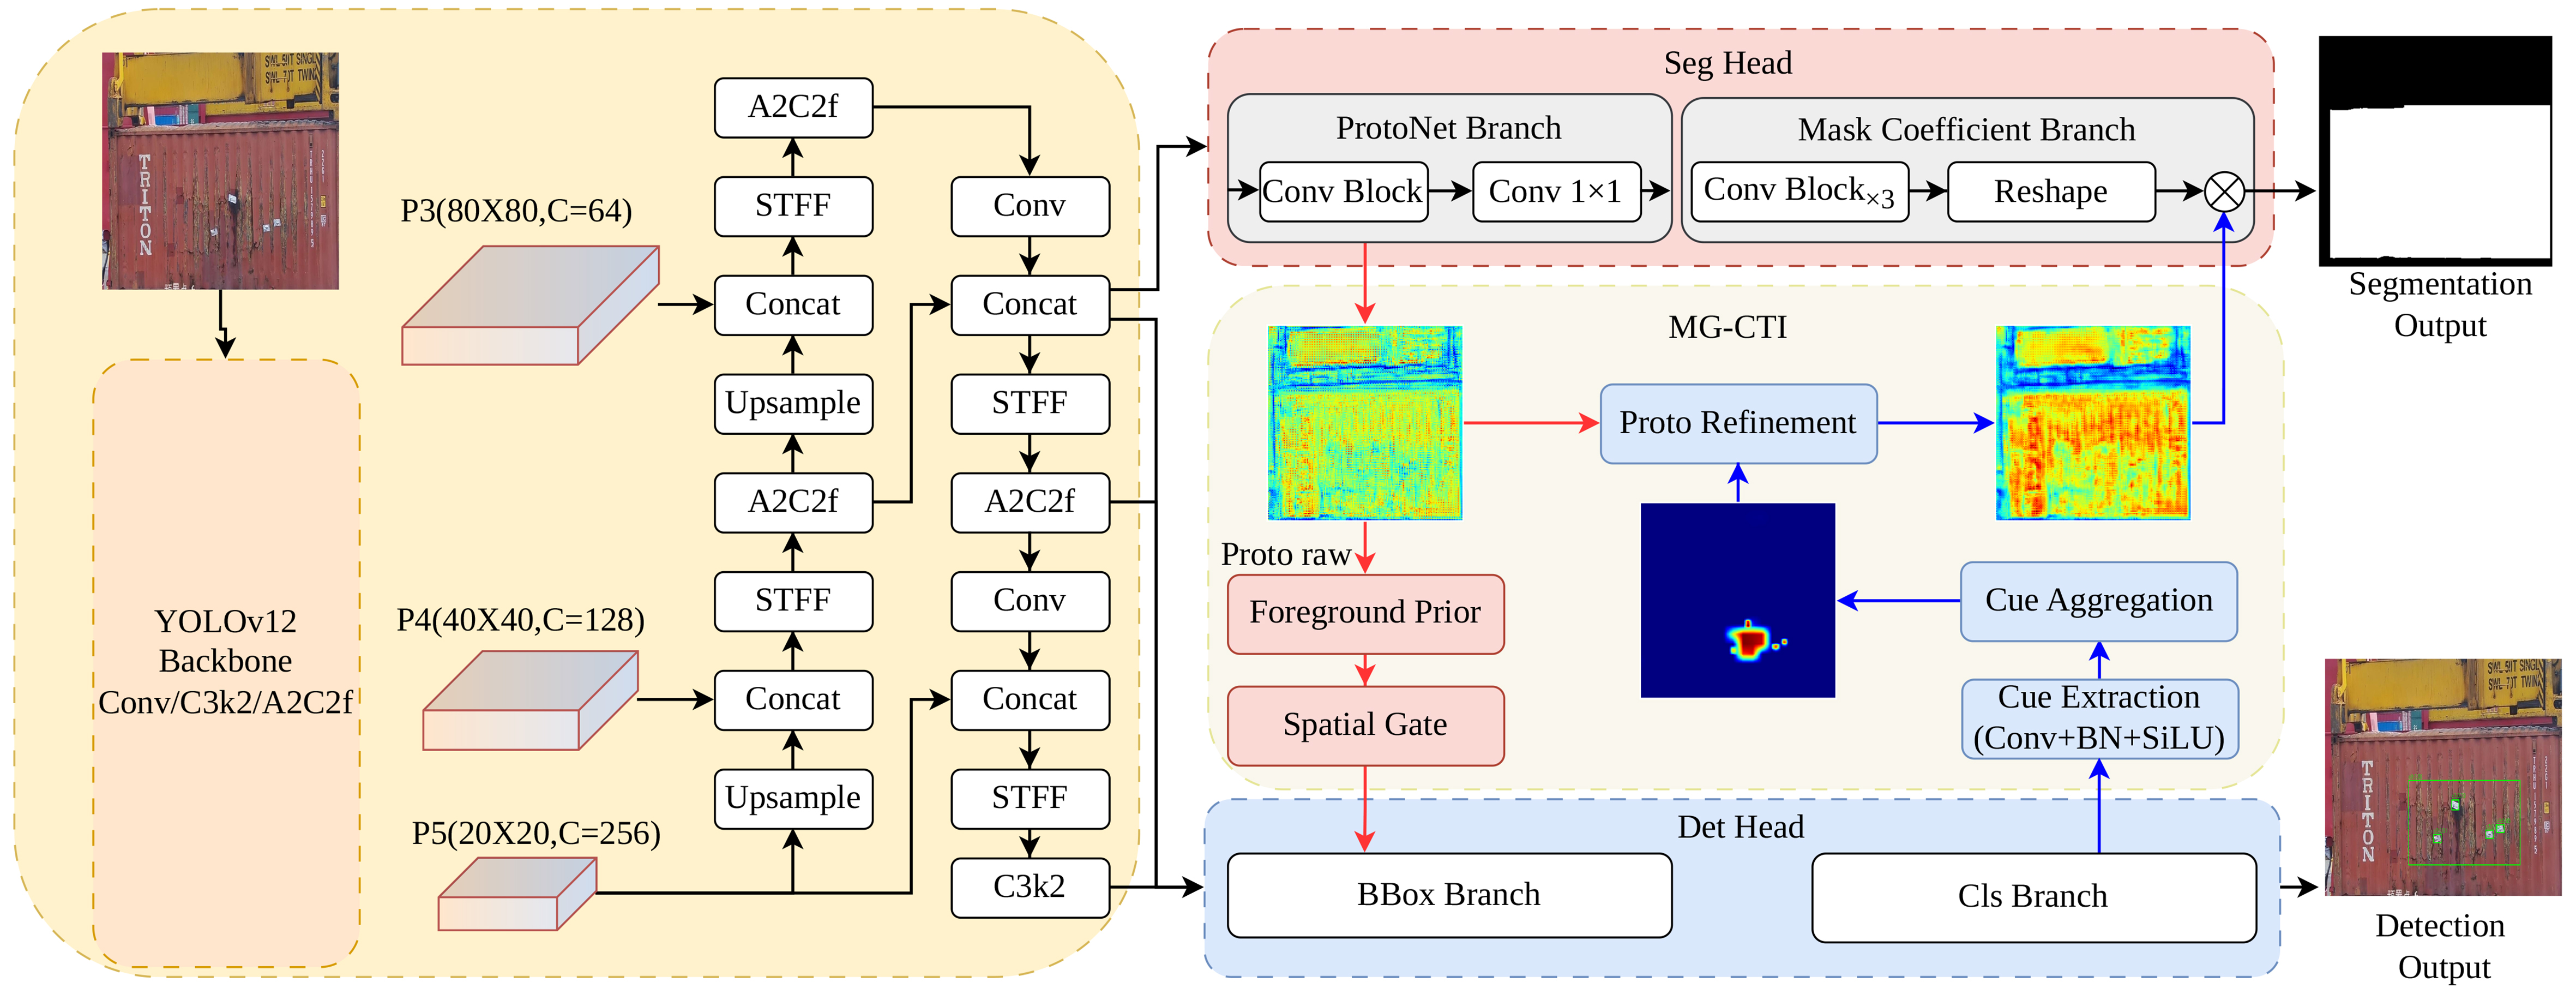
Figure 1. Overall architecture of the proposed container-surface-prior-guided dual-task network. The shared backbone and neck extract multi-scale features, while the detection and segmentation branches are connected through MG-CTI for lightweight bidirectional task interaction. The photographs in the upper-left input and lower-right detection-output panels were acquired at Qianwan Terminal, Port of Qingdao, China. All port photographs shown throughout this article share this source and are reproduced with written permission for journal publication. Detection overlays, annotations, and heatmaps were generated in this study. MG-CTI: Mask-guided cross-task interaction; STFF: scale-tuned feature fusion; Conv: convolution; BBox: bounding box; BN: batch normalization; Cls: classification; SiLU: sigmoid linear unit.