
fig3
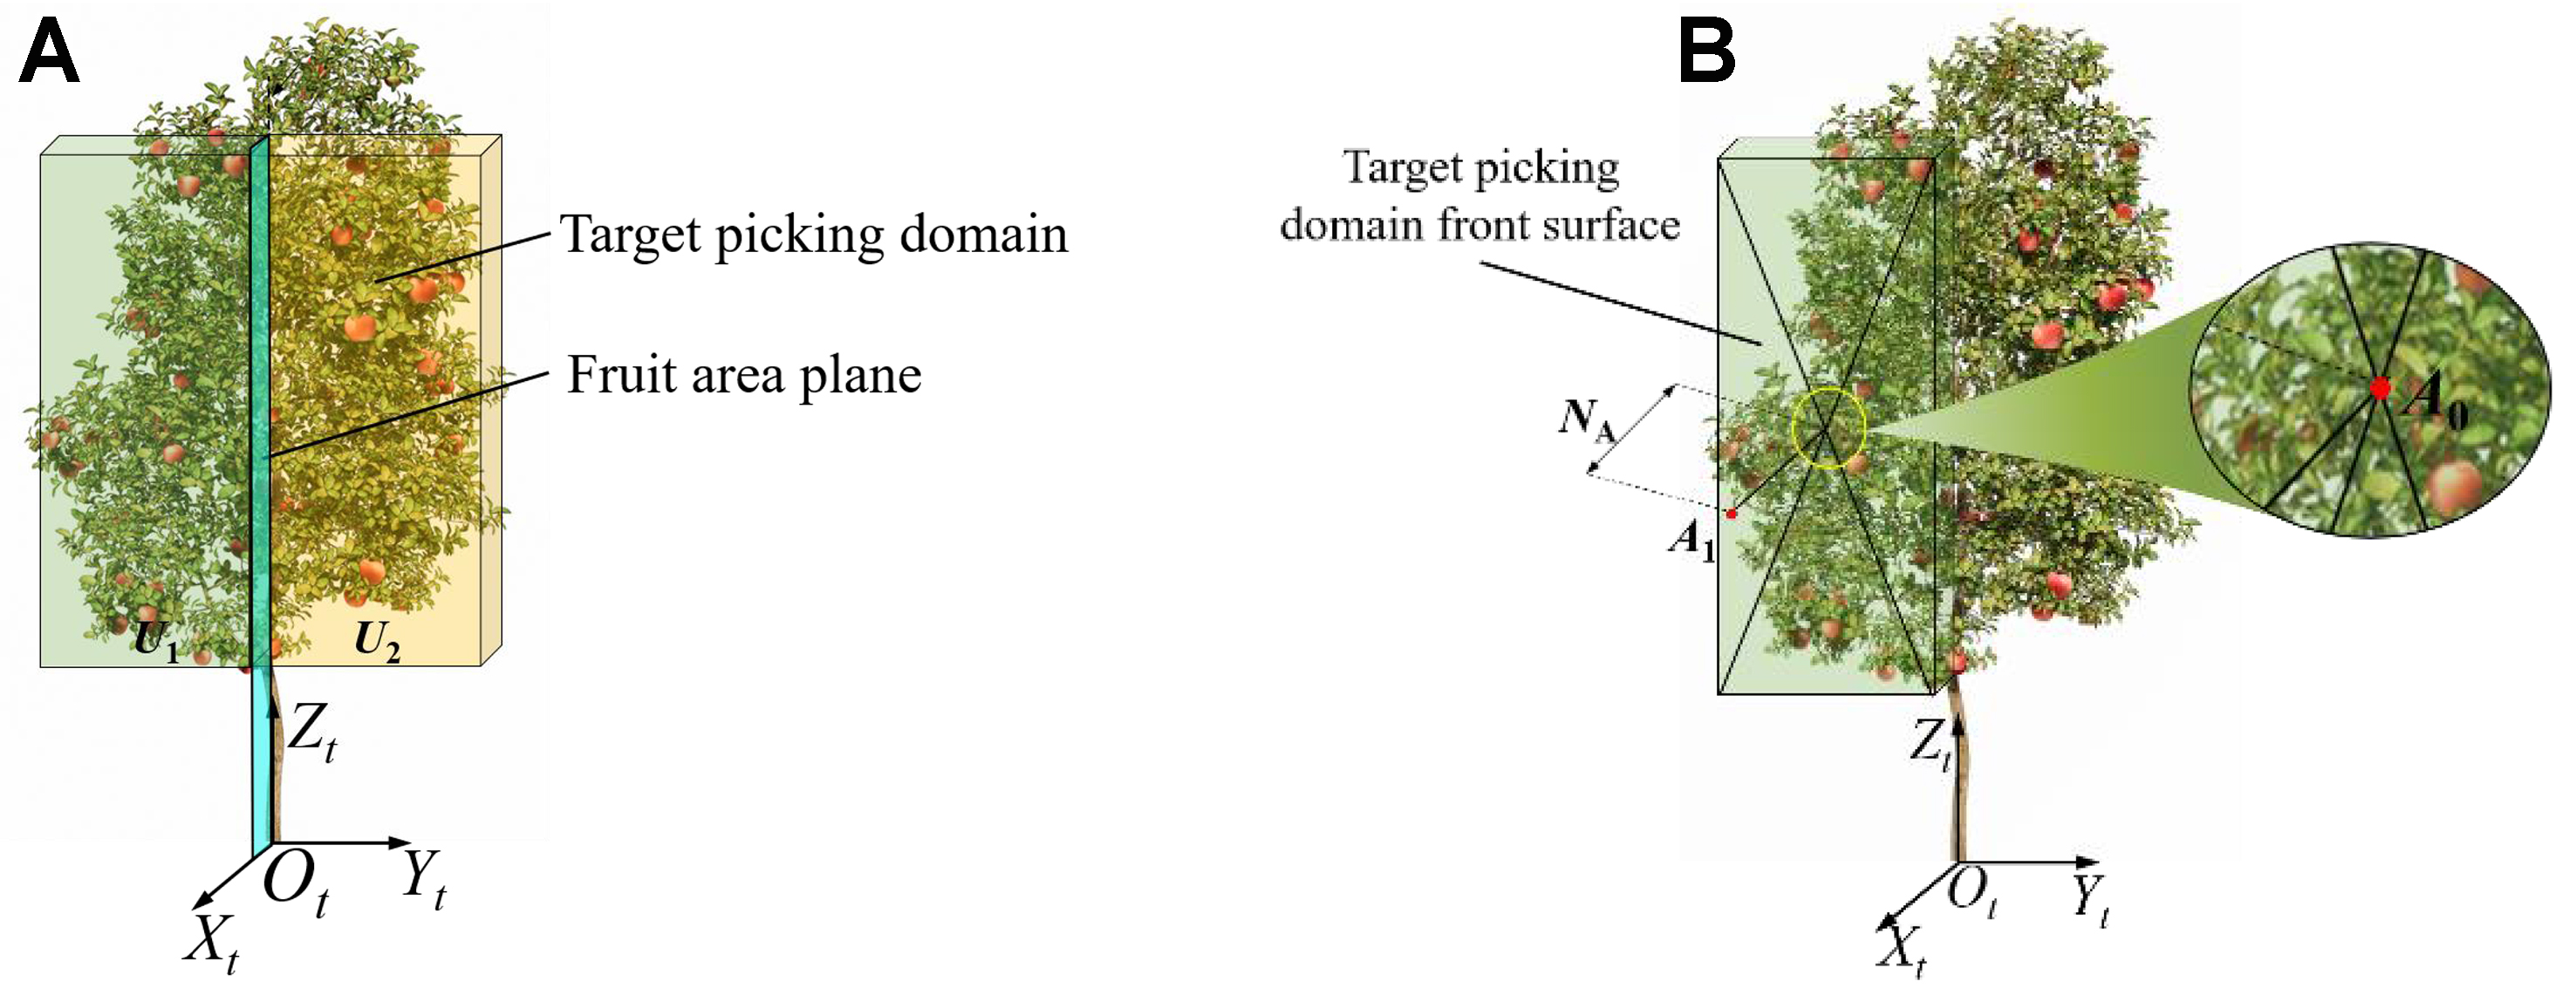
Figure 3. This figure illustrates the partitioning of the picking regions and the definition of the operational base point. (A) Schematic of fruit picking region partitioning; (B) Picking operation base point.
Figure 3. This figure illustrates the partitioning of the picking regions and the definition of the operational base point. (A) Schematic of fruit picking region partitioning; (B) Picking operation base point.


All published articles are preserved here permanently:
https://www.portico.org/publishers/oae/