
fig2
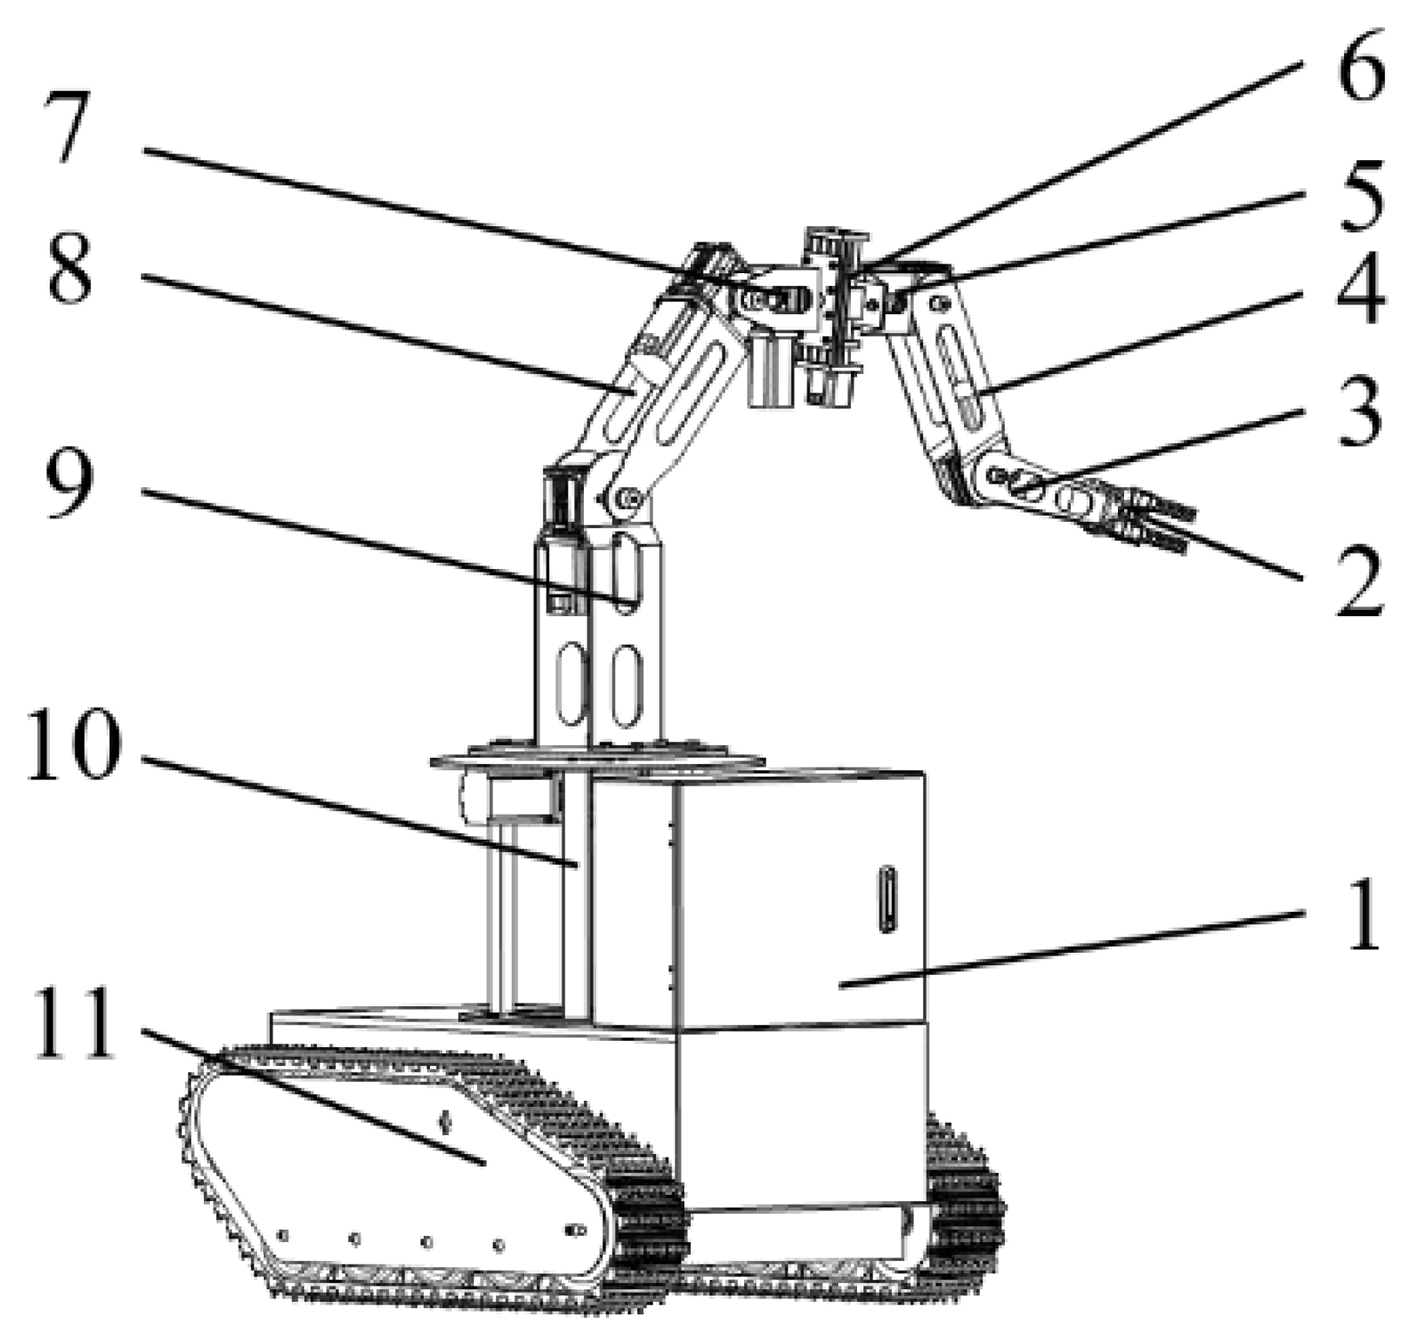
Figure 2. Overall structure of the apple harvesting robot. 1 denotes the control box; 2 denotes the end-effector (gripper); 3 denotes the picking secondary arm; 4 denotes the picking main arm; 5 denotes the translational arm; 6 denotes the rotating secondary arm; 7 denotes the rotating main arm; 8 denotes the lifting arm; 9 denotes the support arm; 10 denotes the frame; and 11 denotes the chassis.