
fig17
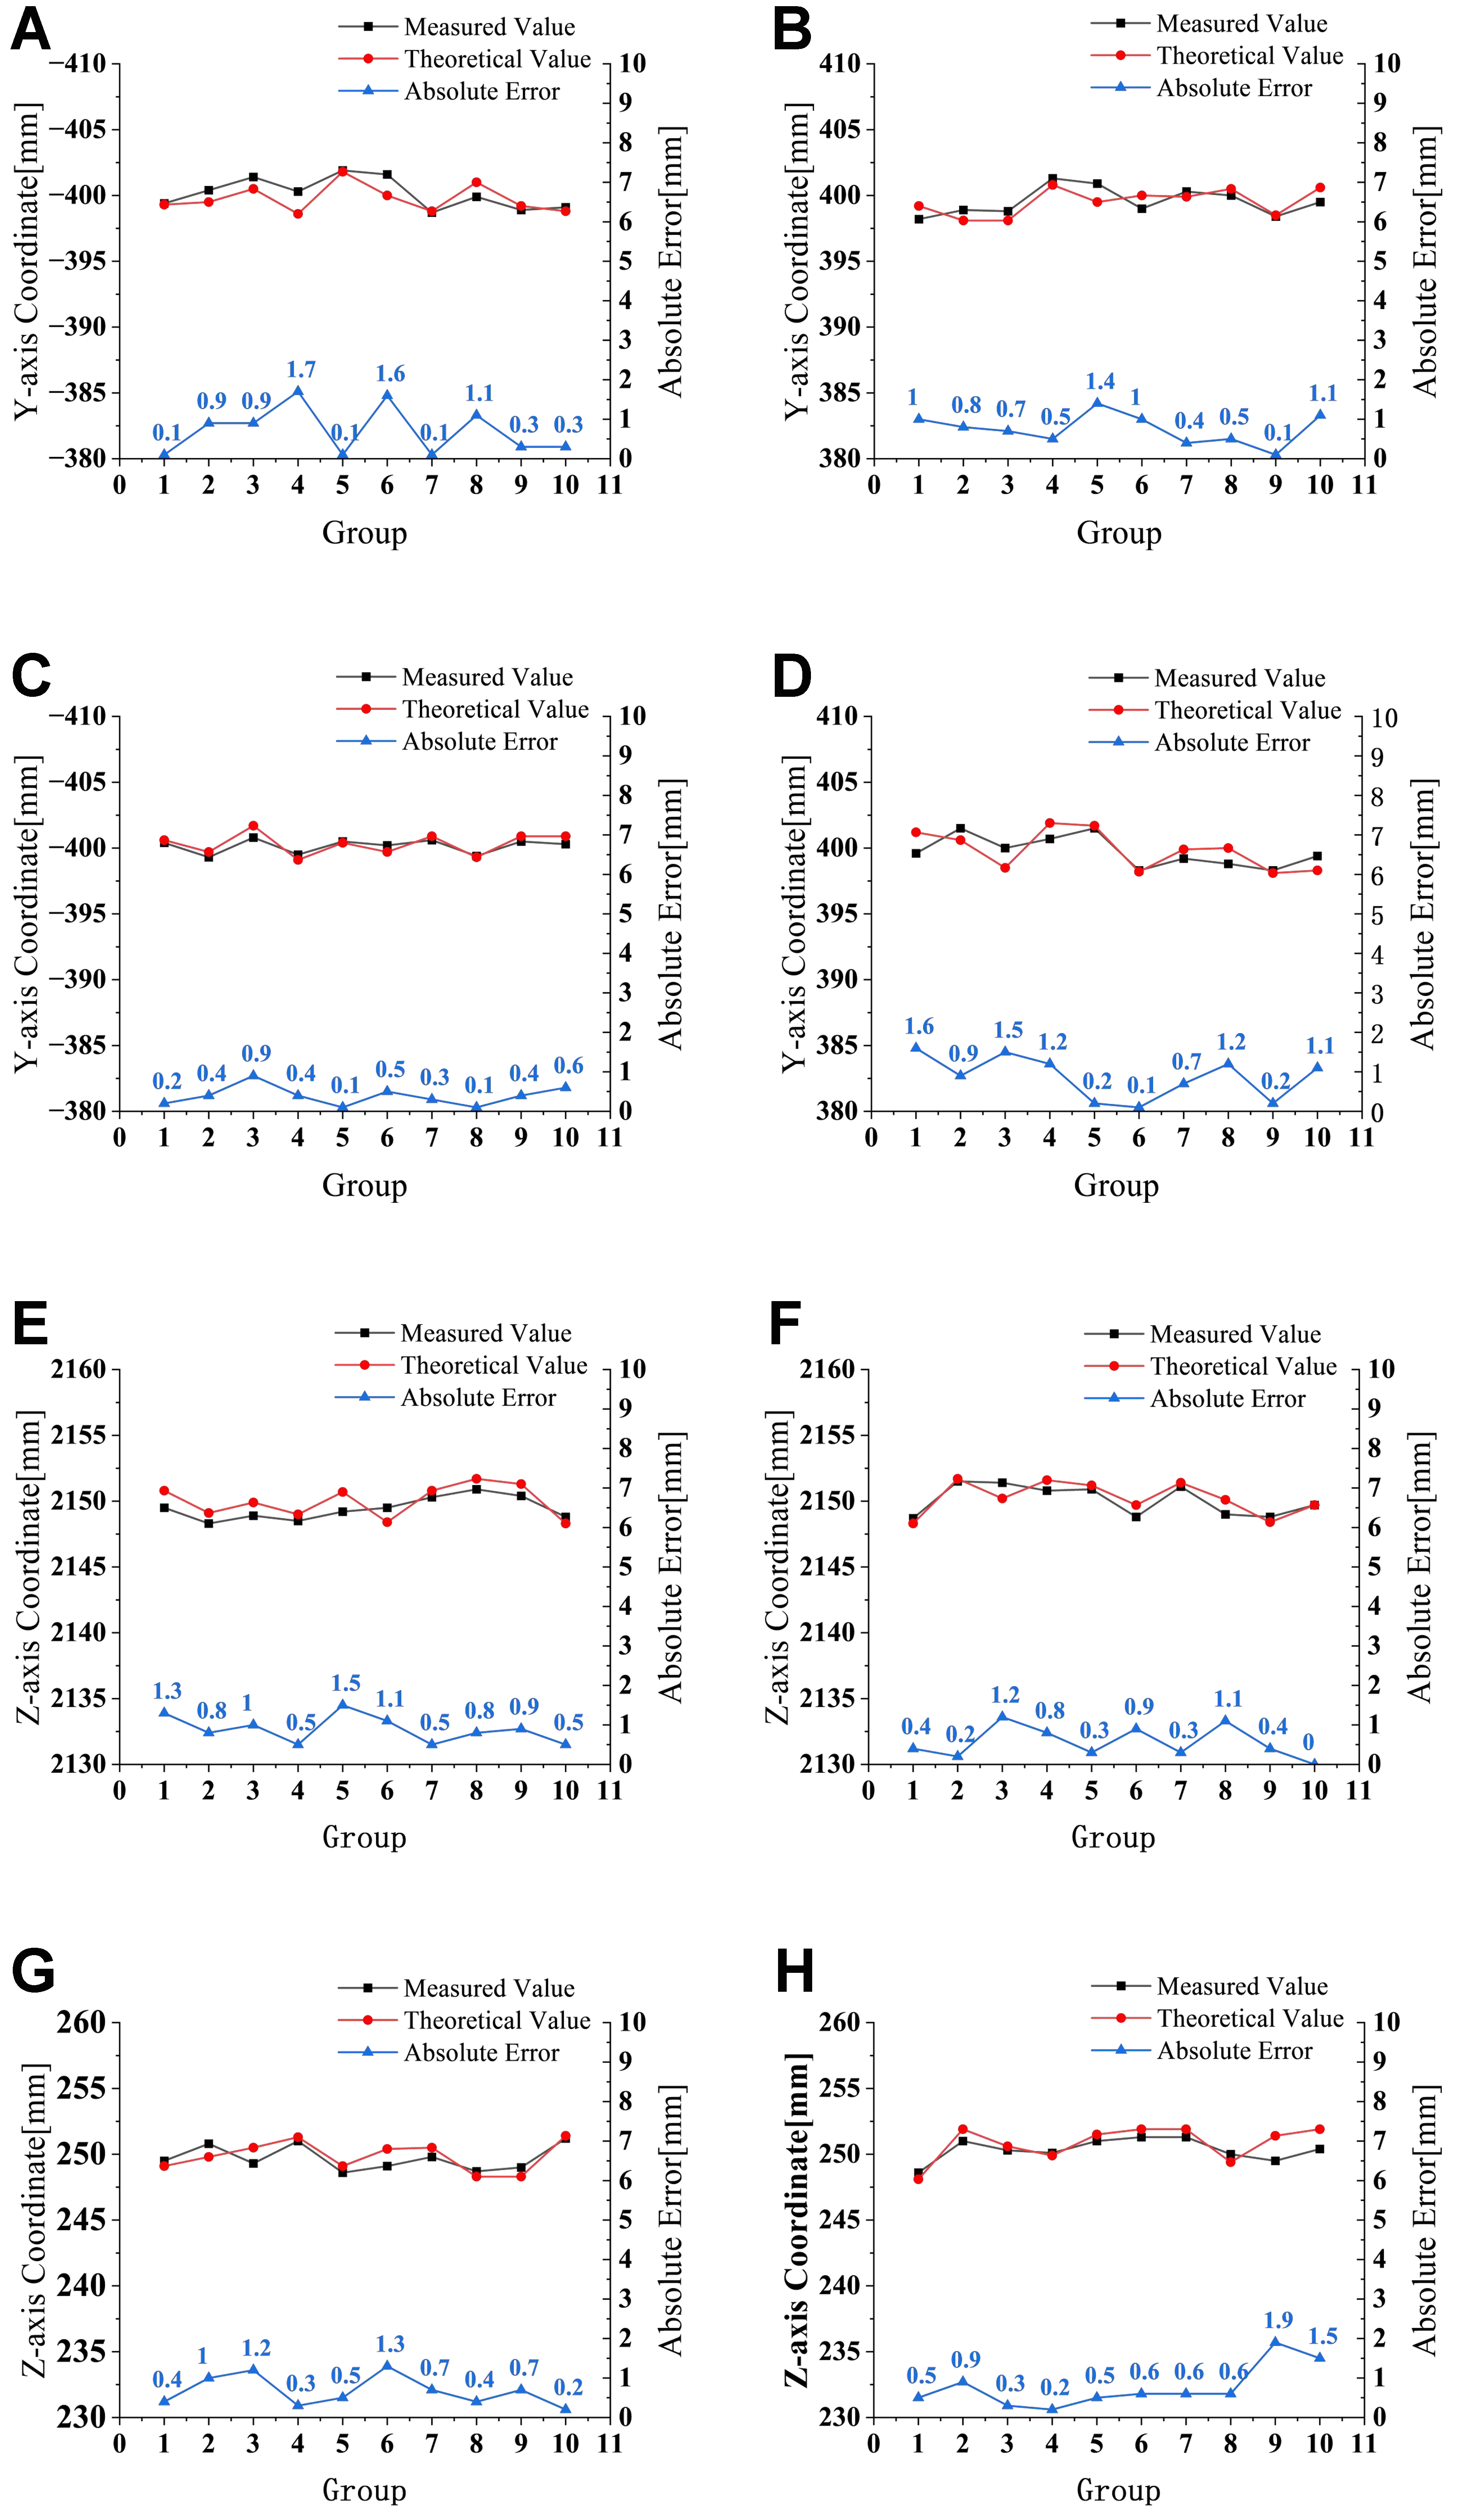
Figure 17. Comparison between measured and theoretical Y- and Z-axis coordinates of boundary reference points in the target picking region: (A-D) Y-axis coordinates of points a1-a4; (E-H) Z-axis coordinates of points a1-a4.
Figure 17. Comparison between measured and theoretical Y- and Z-axis coordinates of boundary reference points in the target picking region: (A-D) Y-axis coordinates of points a1-a4; (E-H) Z-axis coordinates of points a1-a4.


All published articles are preserved here permanently:
https://www.portico.org/publishers/oae/