
fig12
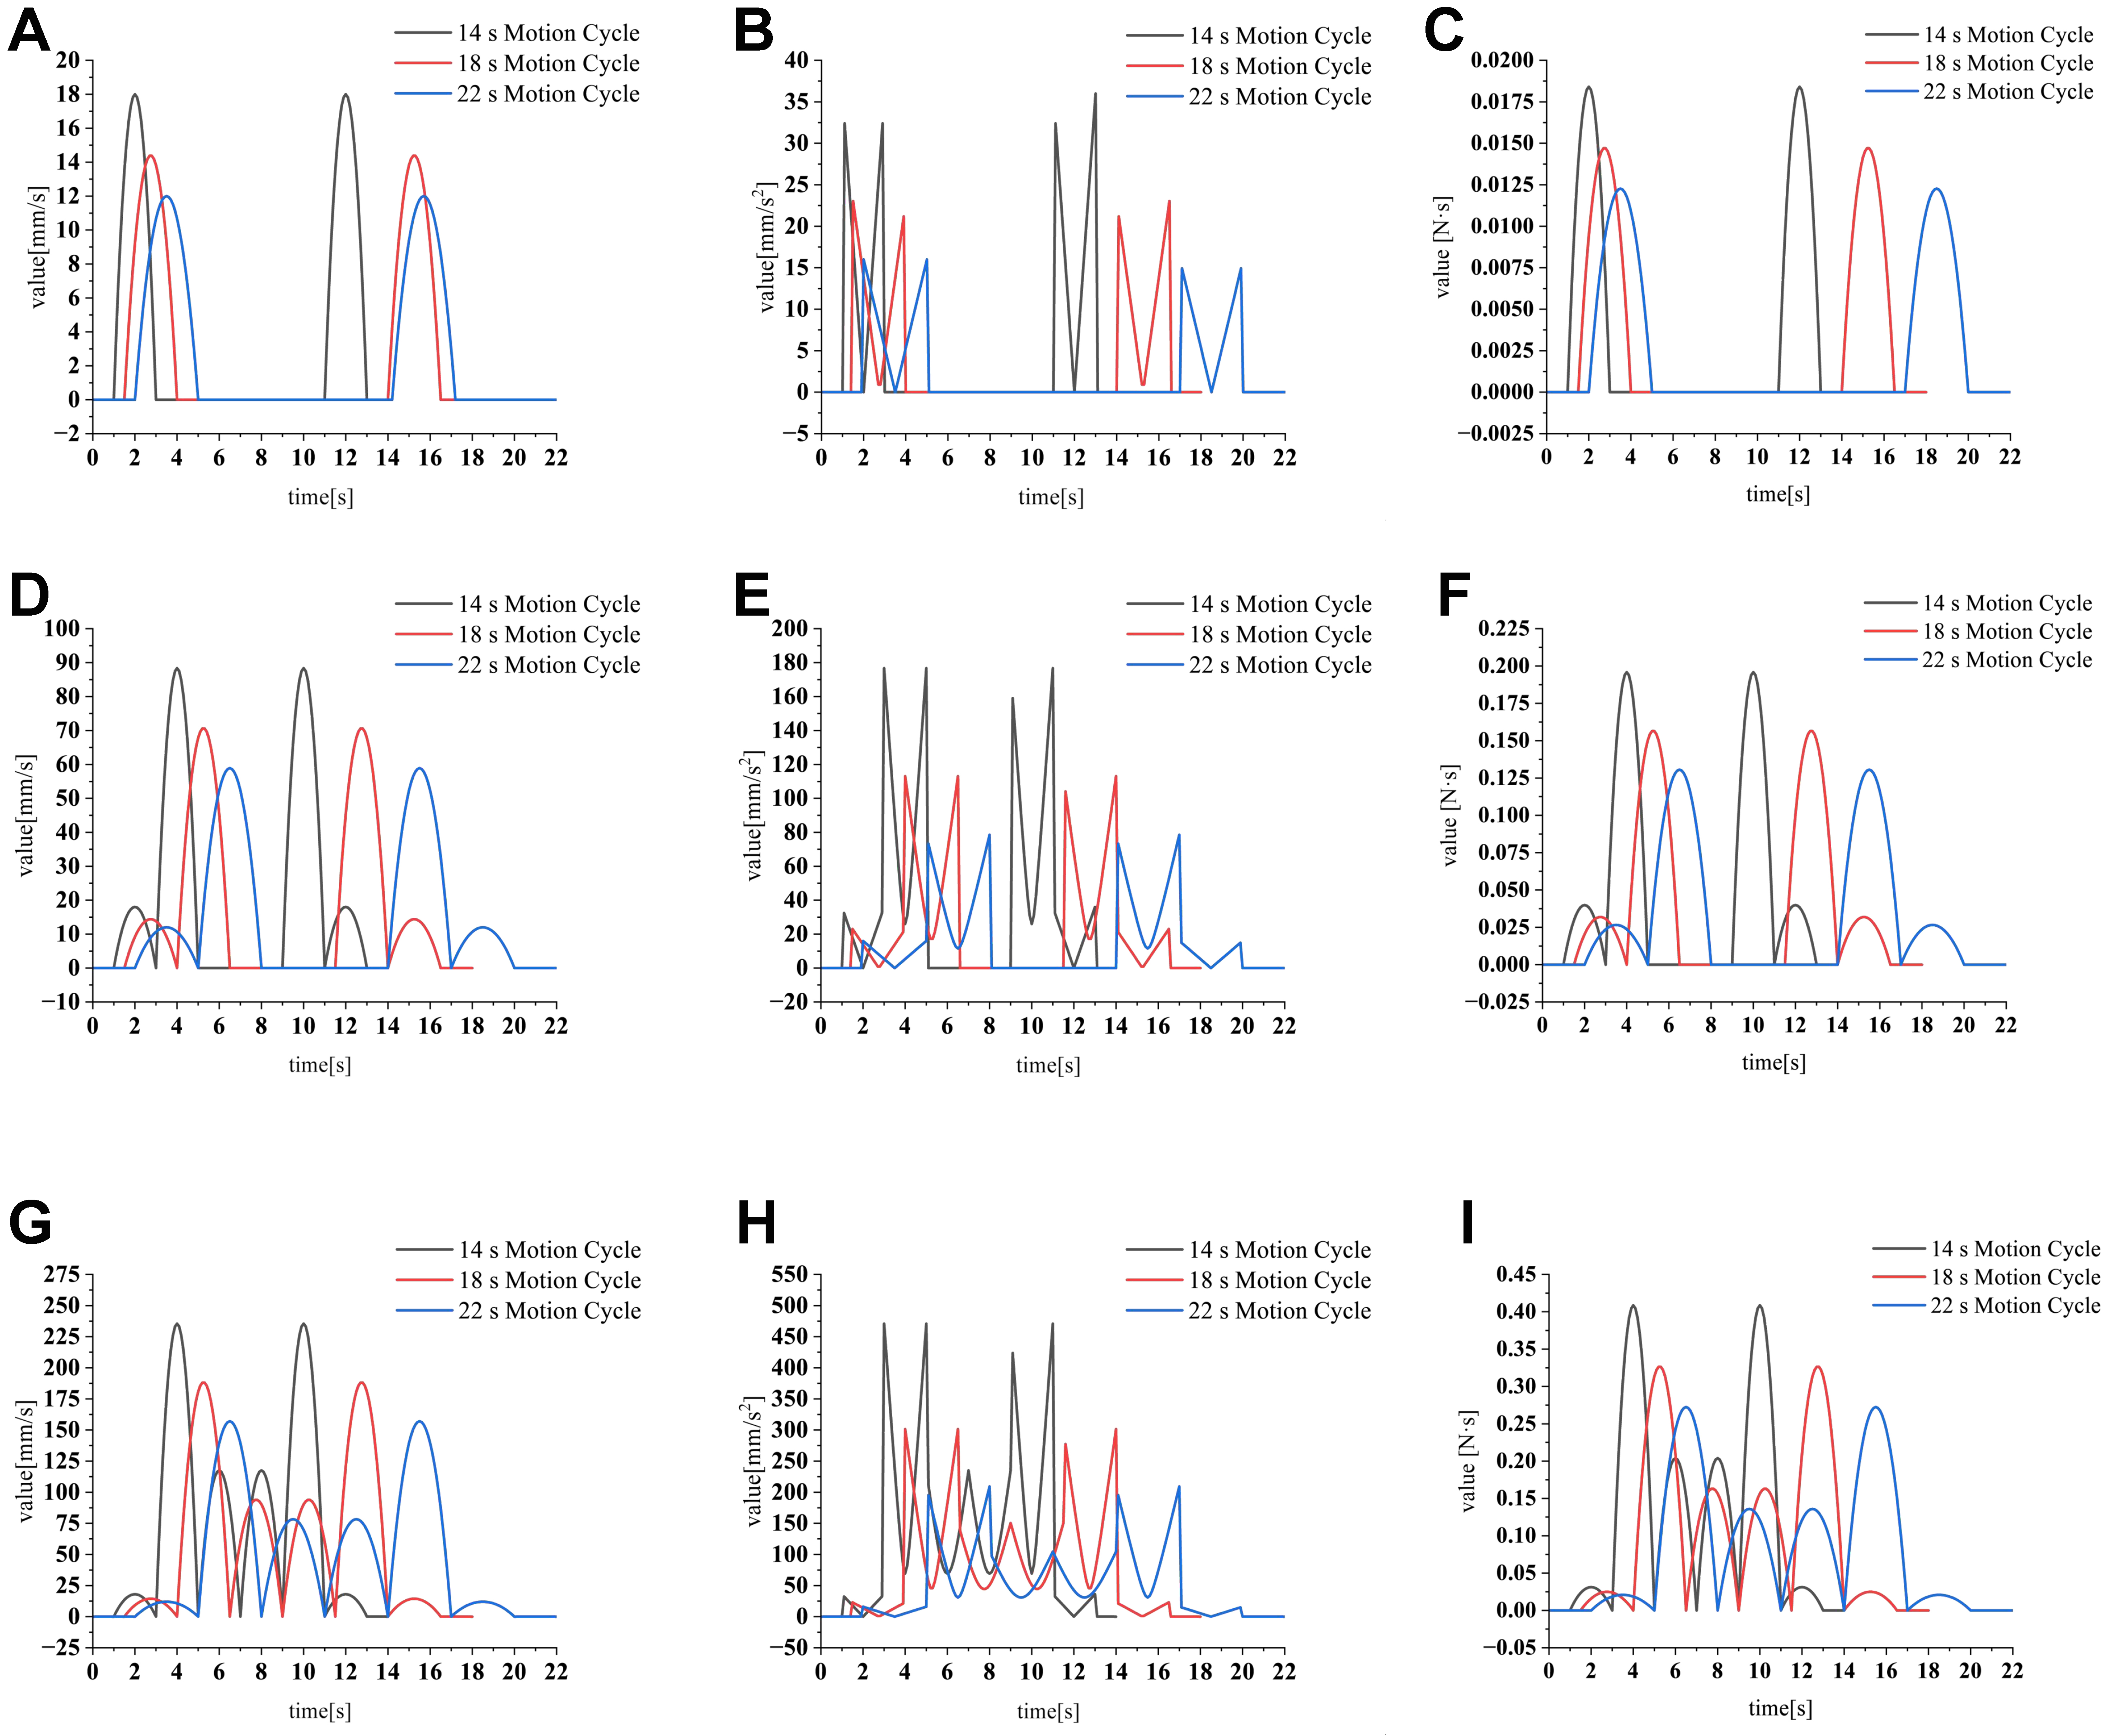
Figure 12. Joint dynamic parameter curves of the picking mechanism. (A) Centroid velocity of the translational arm; (B) Centroid acceleration of the translational arm; (C) Momentum of the translational arm; (D) Centroid velocity of the picking main arm; (E) Centroid acceleration of the picking main arm; (F) Momentum of the picking main arm; (G) Centroid velocity of the picking secondary arm; (H) Centroid acceleration of the picking secondary arm; (I) Momentum of the picking secondary arm.