
fig10
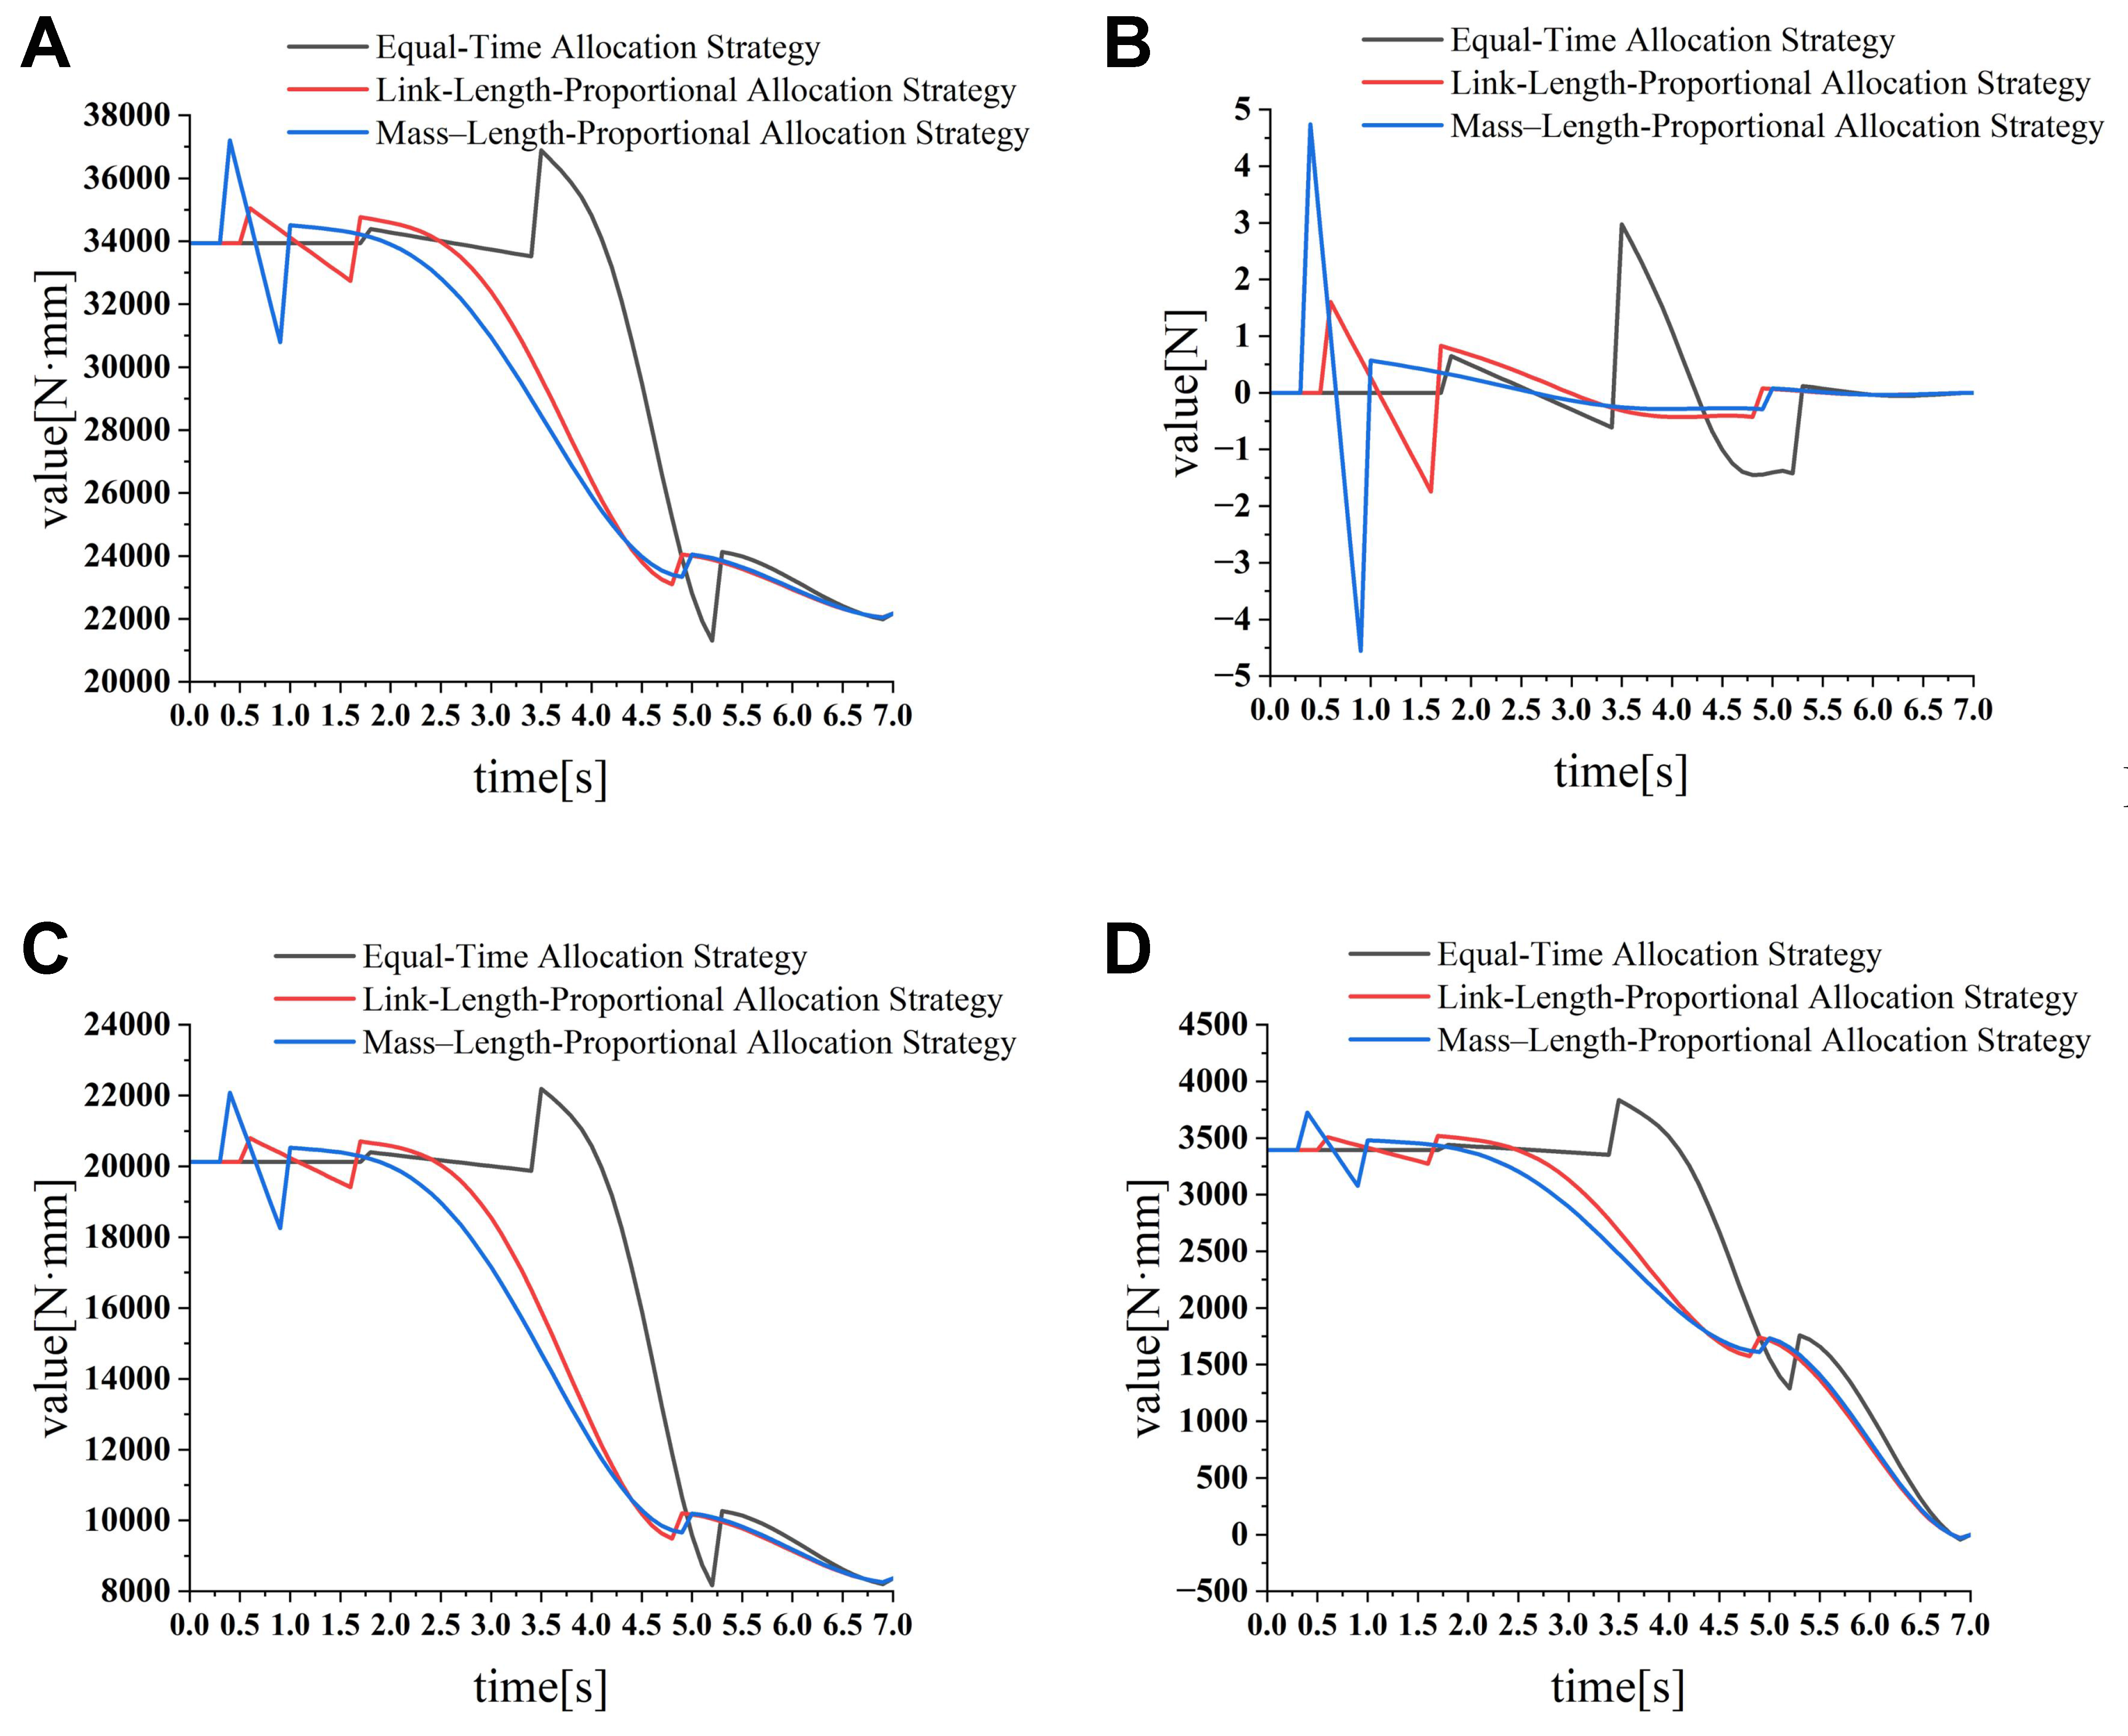
Figure 10. Joint force/torque comparison of each link under different allocation strategies: (A) rotating secondary arm; (B) translational arm; (C) picking main arm; and (D) picking secondary arm.
Figure 10. Joint force/torque comparison of each link under different allocation strategies: (A) rotating secondary arm; (B) translational arm; (C) picking main arm; and (D) picking secondary arm.


All published articles are preserved here permanently:
https://www.portico.org/publishers/oae/