
Figure8
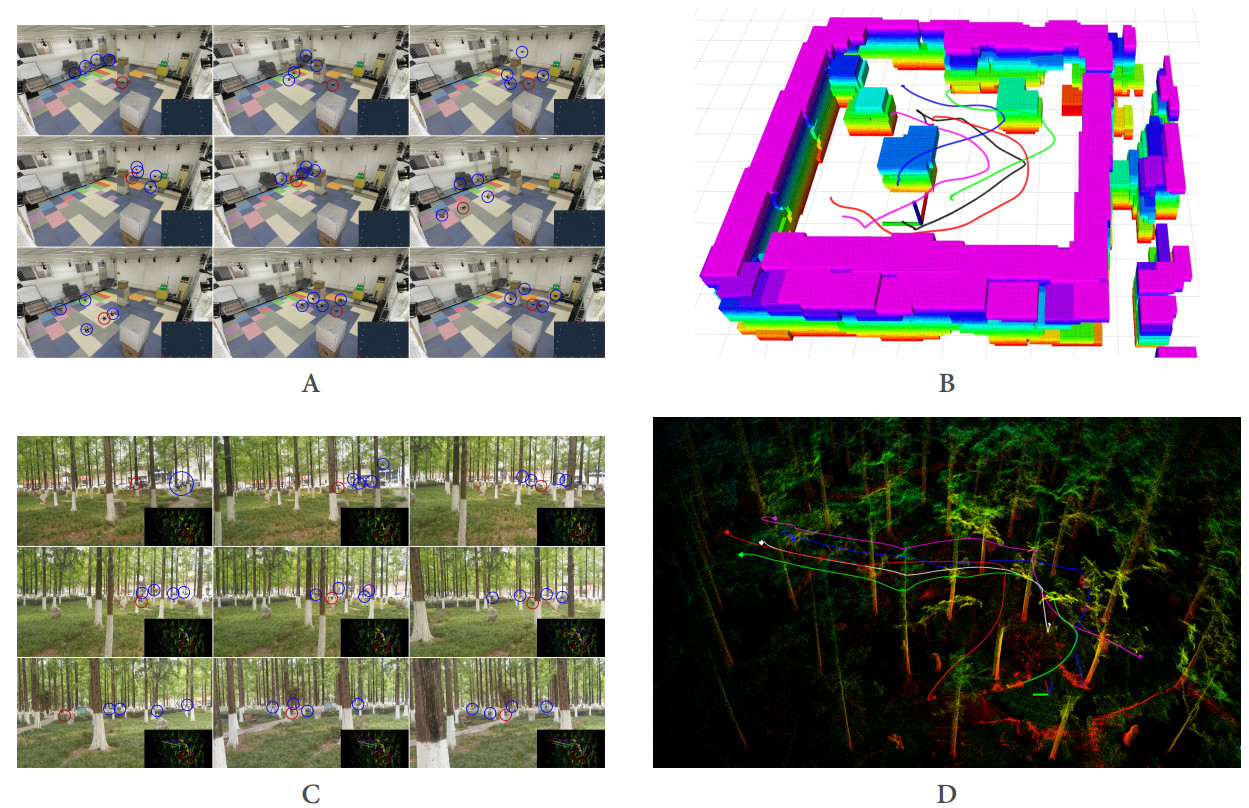
Figure 8. Real-world experiments. (A) Snapshot of the indoor experiment conducted in the motion capture laboratory, where four hunter drones track the target drone. The blue circles represent the hunter drones, and the red circle represents the target drone; (B) Real-time three-dimensional perception and trajectory planning process during the indoor capture experiment. The video of the indoor experiment is provided as Supplementary Video 2; (C) Snapshot of the outdoor experiment in an unknown and cluttered environment; (D) Visualization of trajectories during the outdoor tracking experiment. The video of the outdoor experiment is provided as Supplementary Video 3. Image source: physical experiments and hand-drawn Visio images.