
Figure3
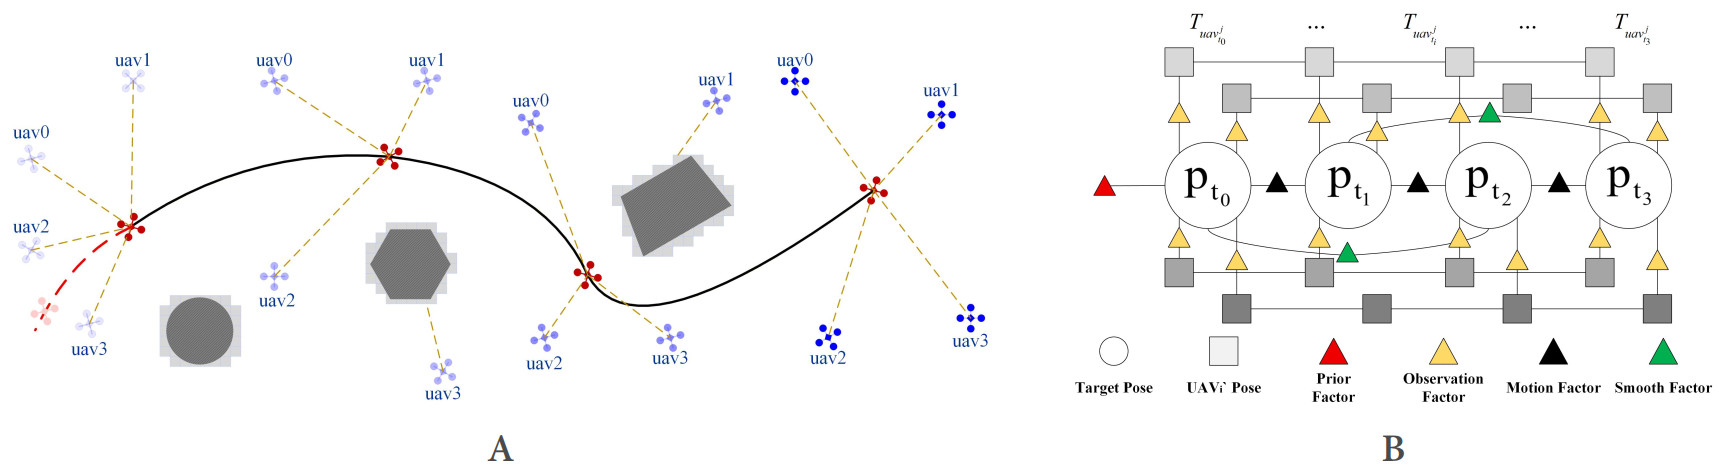
Figure 3. PGO target state estimation. (A) Data acquisition and factor distribution of the active sliding window across four consecutive frames during UAV swarm capture; (B) Factor graph constructed by the PGO method. As the window moves forward, the oldest state is marginalized into the prior residual. The red dashed lines and red triangles represent prior residual information; the yellow dashed lines and yellow triangles represent observation residuals; the black trajectory and black triangles represent motion residuals; and the green triangles represent the smoothing residuals of the optimized trajectory. PGO: Pose graph optimization; UAV: unmanned aerial vehicle.