
fig1
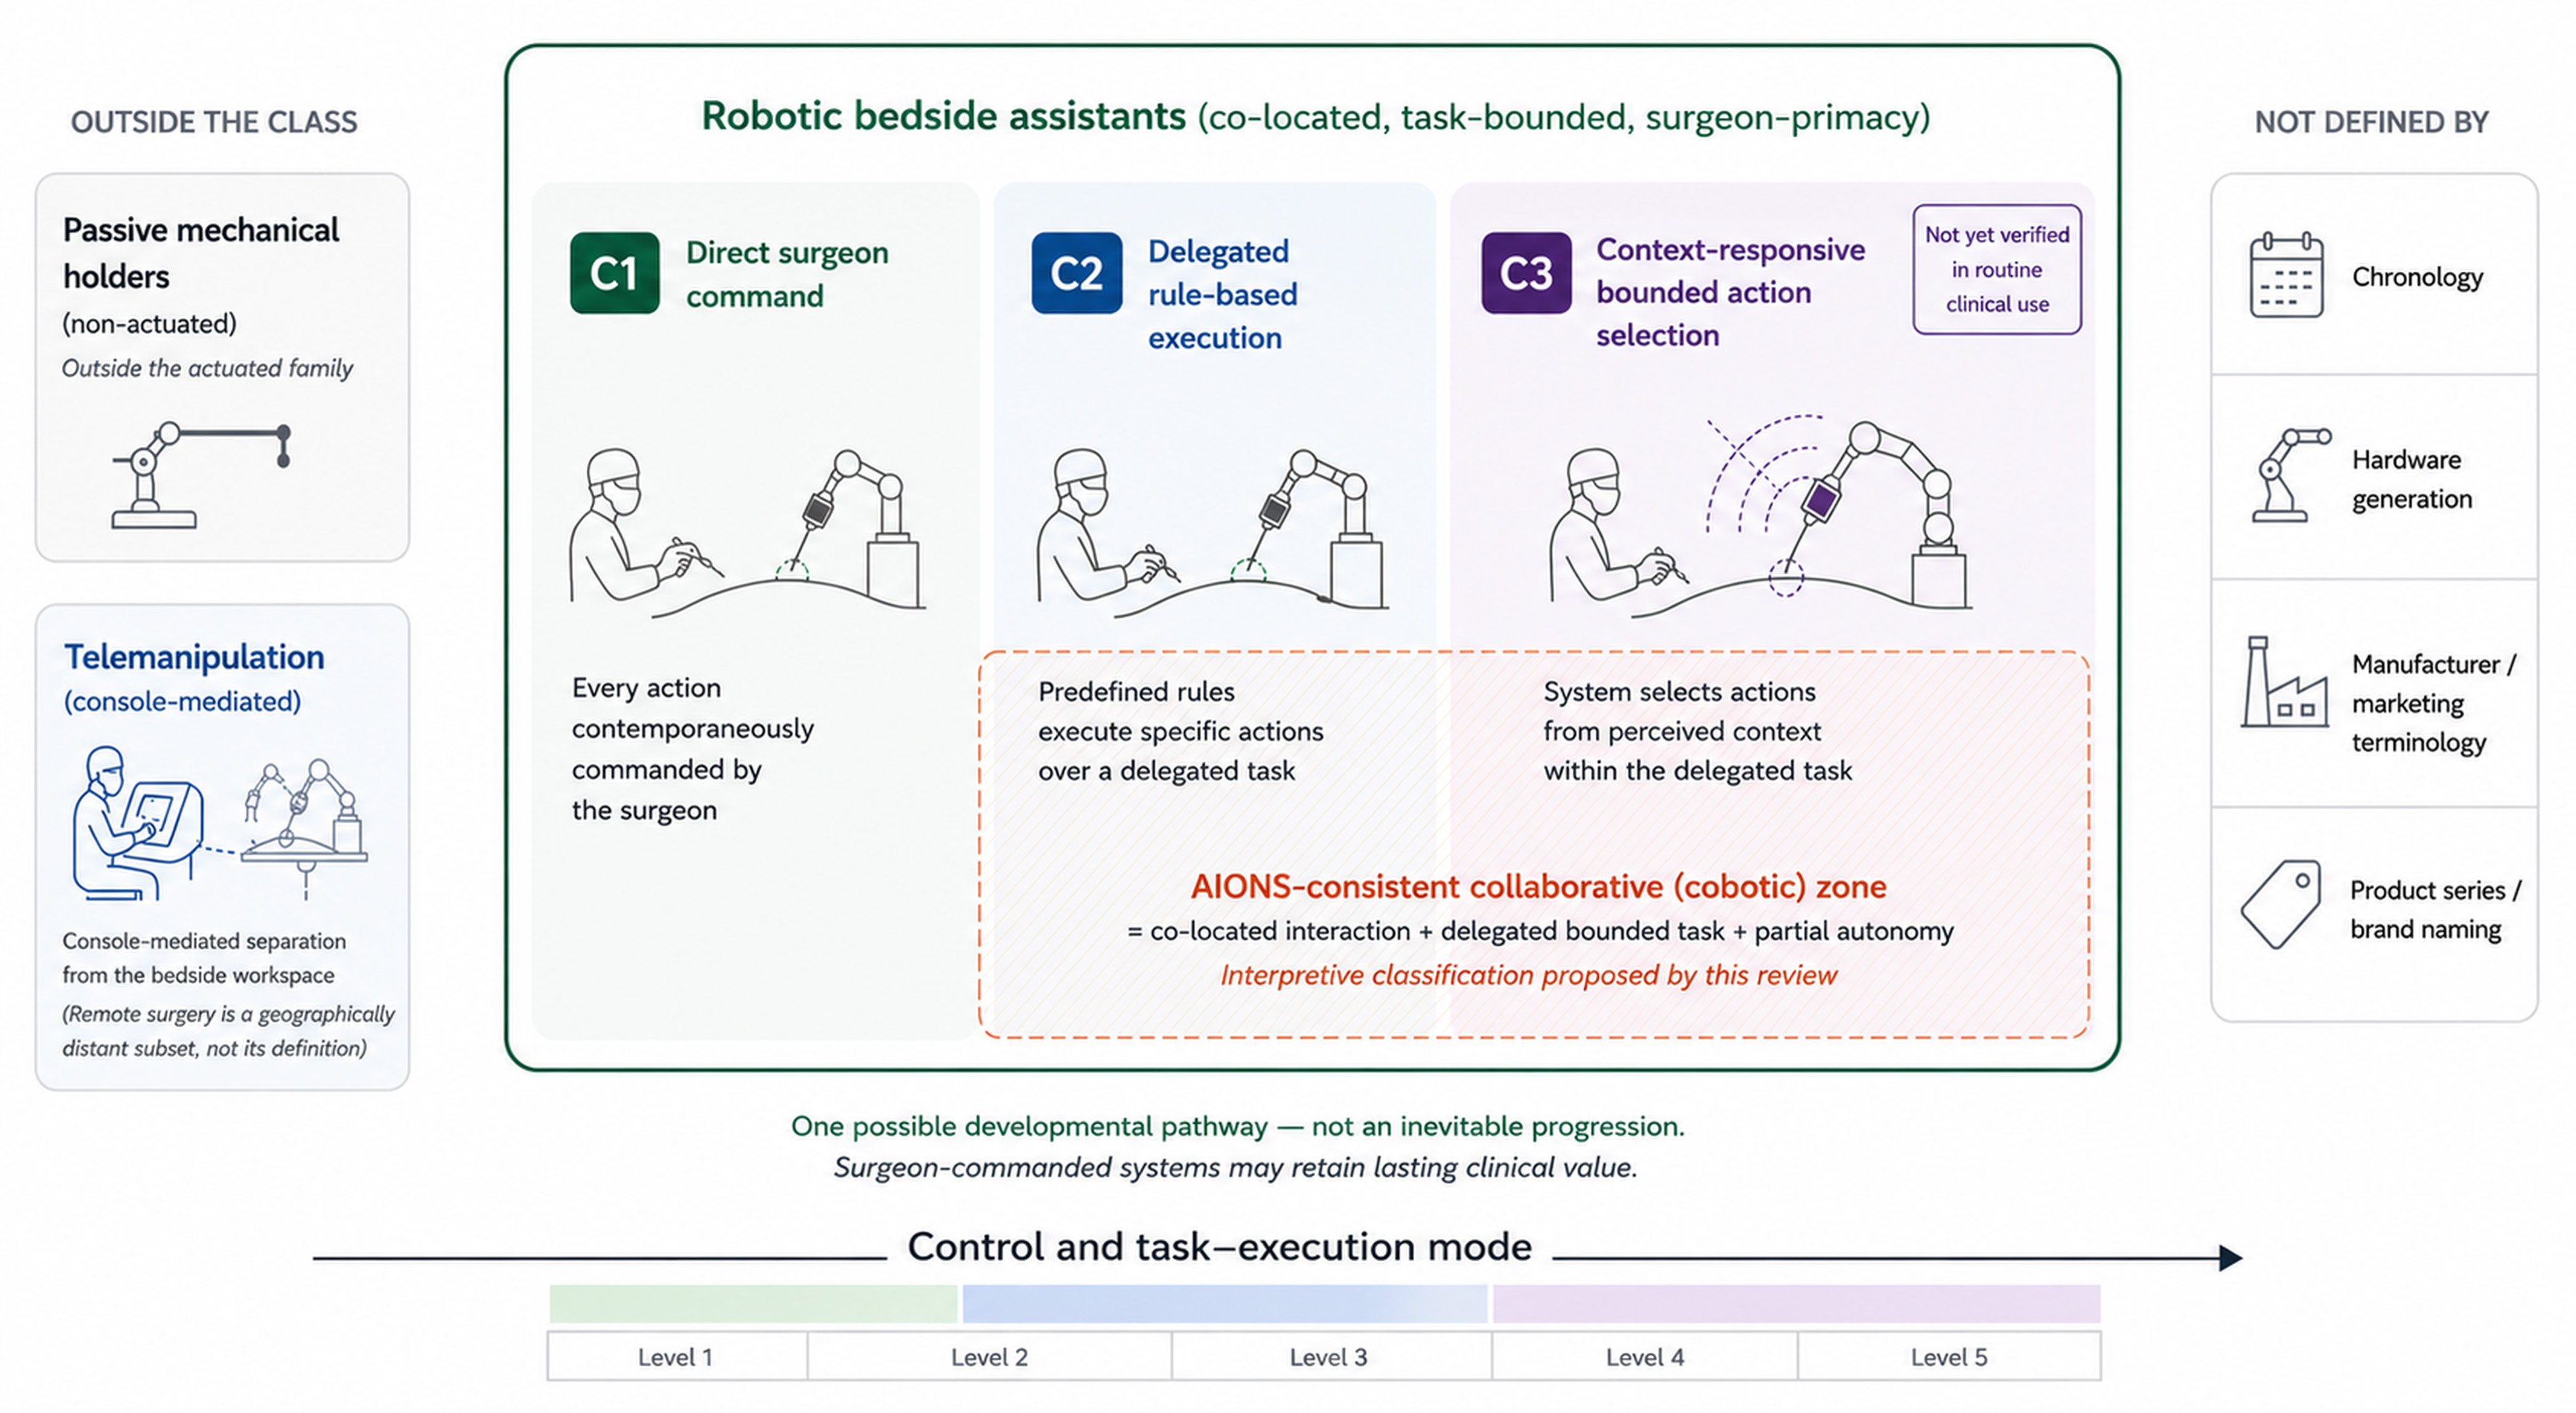
Figure 1. The robotic bedside-assistant class, organized by control and task-execution mode. Robotic bedside assistants constitute a distinct class of surgical robotics defined by operative continuity, co-located interaction, task-bounded assistance, and surgeon primacy. Within this class, systems are classified according to C1, C2, and C3. Passive mechanical holders and telemanipulation lie outside the class, while hardware generation, chronology, and manufacturer terminology are not classification criteria. The shaded overlay indicates the AIONS-consistent collaborative (cobotic) surgery zone as interpreted in this review. C3 represents the proposed future boundary of the framework and remains unverified in routine clinical practice. The developmental pathway illustrates one possible direction of evolution rather than an inevitable progression, and the LASR strip is shown only as an approximate reference. C1: Direct surgeon command; C2: Delegated rule-based execution; C3: context-responsive bounded action selection; LASR: Levels of Autonomy in Surgical Robotics.